Robotic Flying Squirrel
Project Status
This was a conceptual prototype developed in my final year of University in 2020, studying Design Engineering at Imperial College London.
Skills
-
Biomimicry
Market research
Technology research
Stakeholder interviews
Ideating
-
Snap fits
Linkage design and optimisation
Design for assembly
Design for additive manufacture
-
Solid modelling (SolidWorks)
Rendering (KeyShot)
-
3D printing
Microelectronics (Arduino)
Testing
Data analysis
Computer vision (Matlab)
Prototyping Gliding
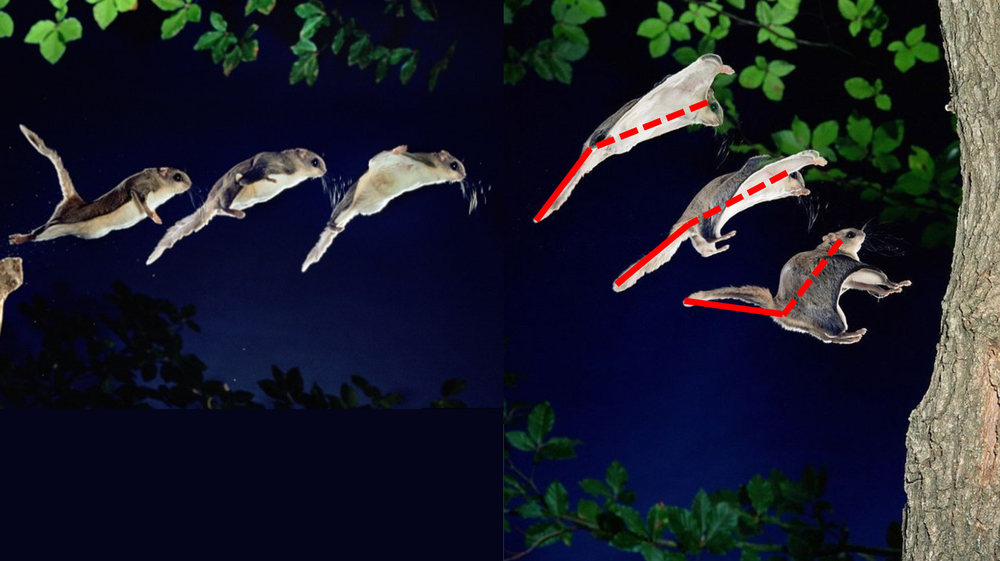
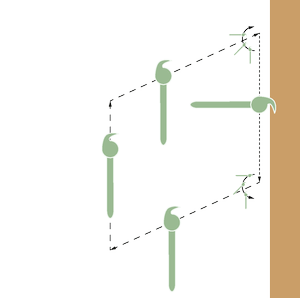
Flying squirrels are both efficient climbers and good gliders, so I decided to use biomimicry to try and influence my design. Through analysing their flight, it can be seen that they use their tail to adjust their orientation as they’re about to land, in order to both slow down and to land vertically (a process called “vortex shedding”). They also use their legs to both climb and glide.
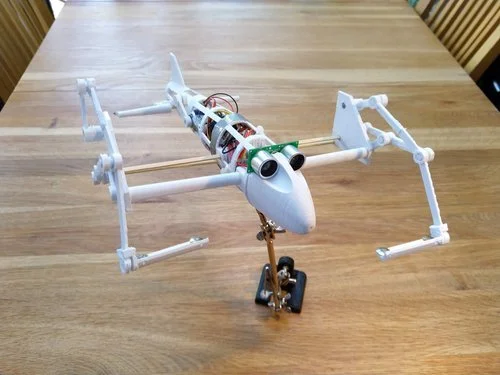
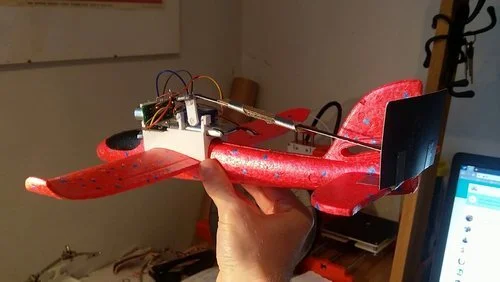
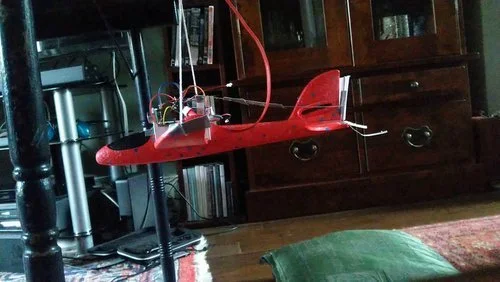
I created an experiment to recreate behaviour robotically. I used an off-the-shelf glider, and attached an ultrasonic sensor to measure the distance to the landing surface, and PID control was used with this input to control the glider’s landing. A hair dryer was used to simulate airflow so the PID controller could be tuned, to ensure the glider would land vertically every time.
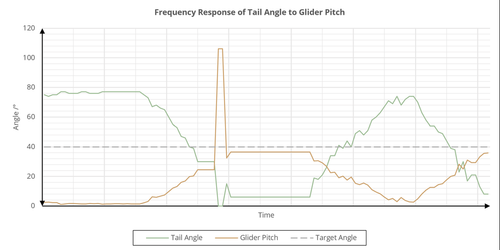
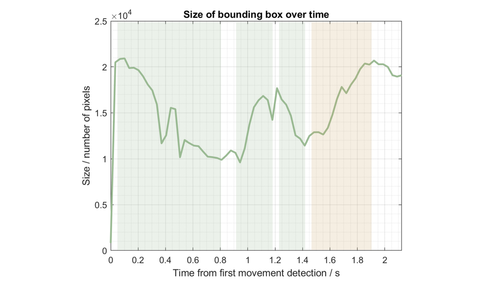
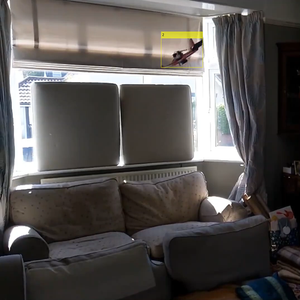
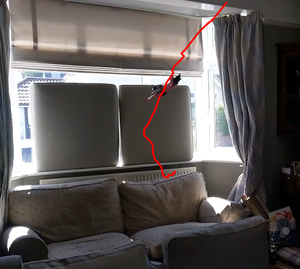
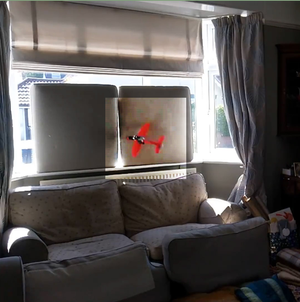
The glider approaches the landing surface, increases the angle of its rear wing in response, and successfully lands on the surface vertically. I used computer vision in Matlab to analyse the glider’s path and confirm that the glider was slowing down as it approached the landing surface and measure the glider’s flight path.
Prototyping Climbing
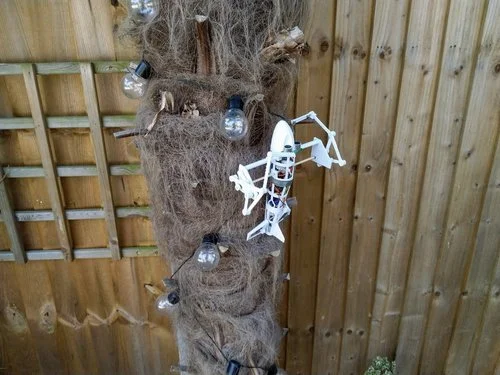
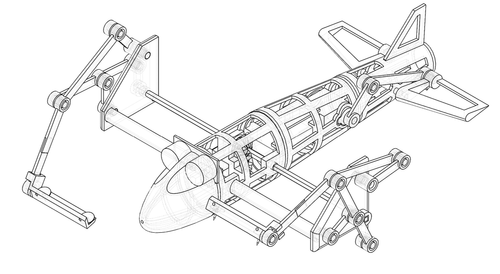
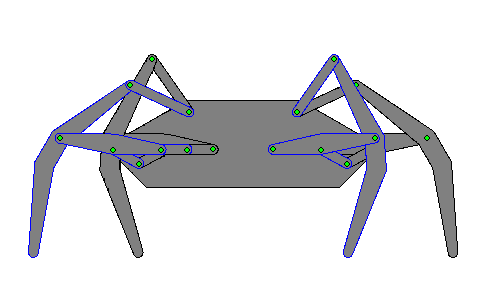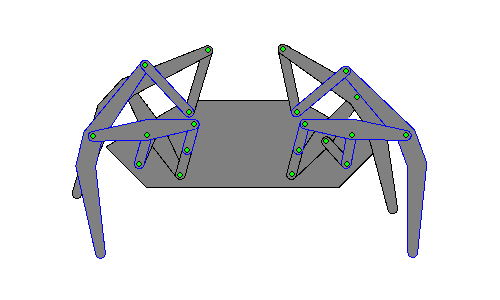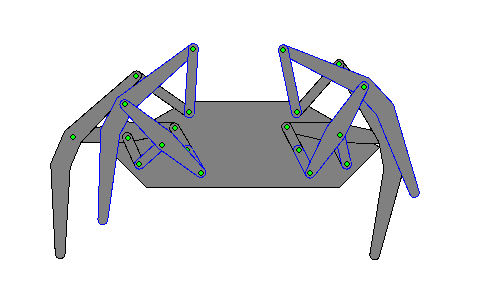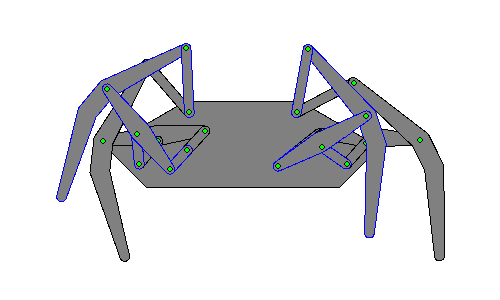
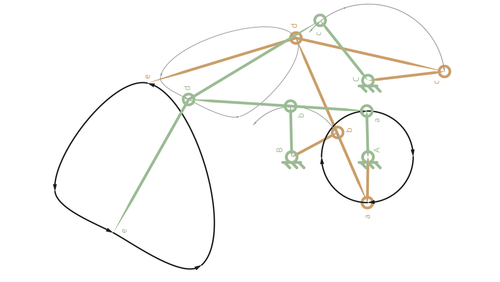
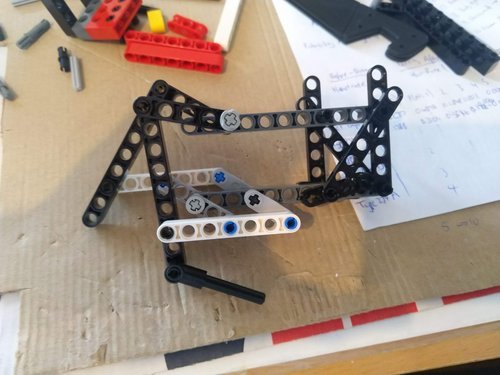
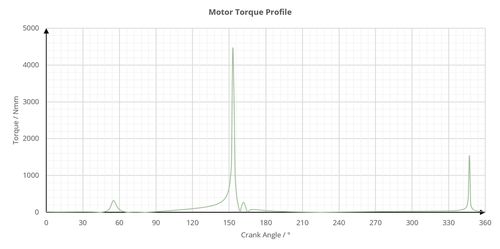
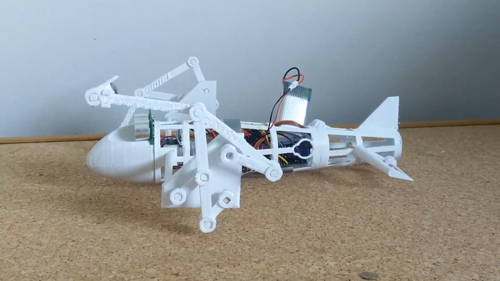
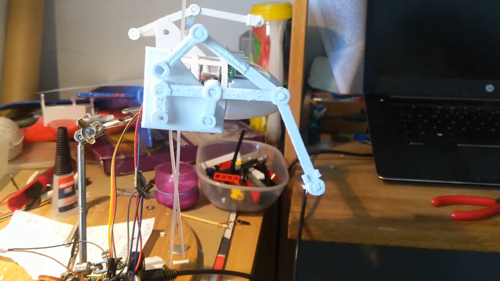
The climbing mechanism had to be as simple as possible, to save power and weight. The climbing is completed by a single motor, to control a linkage for each leg, contra-synchronised from each other. The linkage controlled “feet” of the robot such that the feet would be able to hook themselves into the climbing surface. The mechanism ultimately used was a “Klann” linkage.
Final Prototype
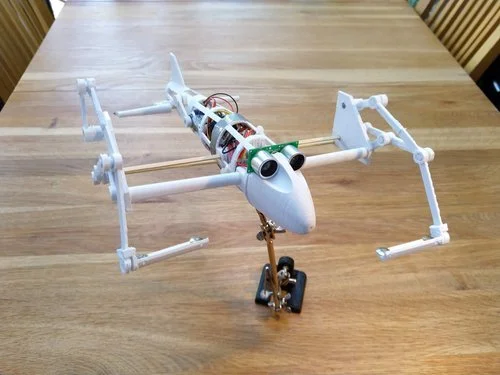
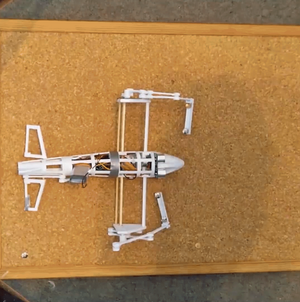
The design was 3D printed and snap fit together for rudimentary real-world testing as a complete unit. All components snap fit together to make repairs and assembly quicker. The main body and wings of the robot are wrapped in a thin sheet or film. Standard, readily available off-the-shelf electronic components were used as much as possible.